Bring your data in.
Cameras, CAN/CAN FD, Ethernet, LiDAR, GNSS, UART, audio, MIDI, databases, external applications. Connect any data source through dedicated nodes.
Yet One Distributed Processing System
A modular framework for distributed data acquisition, processing, visualization, and recording.
Connect sensors, run your C/C++ functions, integrate nodes written in other languages, and inspect the results. Live or replayed. On your desktop or target hardware.
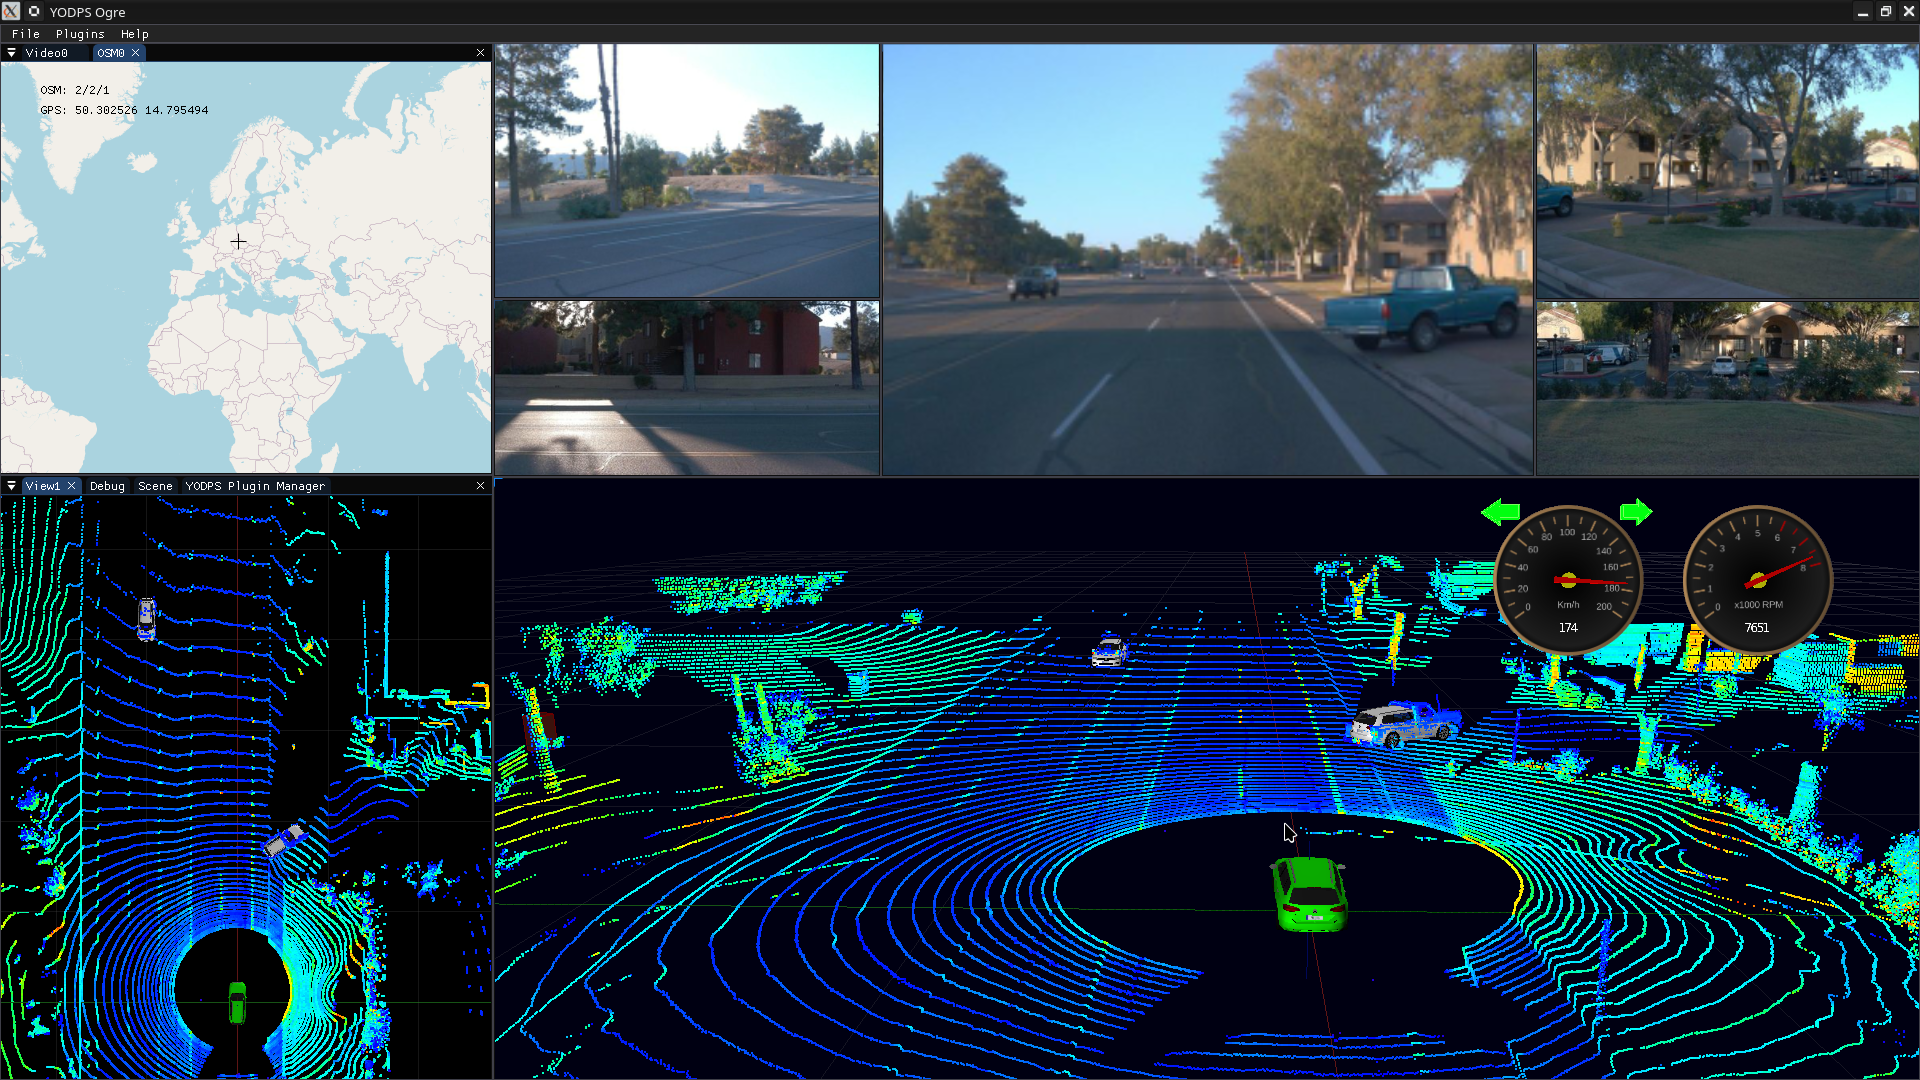 YOViewer / Ogre3D Explore screenshots ↗
One workflow, from sensor to insight
Cameras, CAN/CAN FD, Ethernet, LiDAR, GNSS, UART, audio, MIDI, databases, external applications. Connect any data source through dedicated nodes.
Distributed publish/subscribe messaging with TCP, IPC and shared memory. Wrap your functions as nodes and build processing pipelines, from custom algorithms to AI/ML inference.
3D models, geometry, point clouds, video, maps, CAN signals and structured data inspection with signal plotting in one extensible viewer. Record and replay with MCAP, ADTF DAT and PCAP.
Send data and commands to hardware, simulators and applications, locally or across networked hosts. Build feedback loops that turn processing results into actions.
Built for integration
Move between live sensors, recorded traces and simulation while keeping your processing functions reusable.